
手検出
インスタンスの宣言
手検出(HandDetection) ブロックを作業領域に追加すると、Python コードには次のようなインスタンスの宣言が自動的に挿入されます:
python
hand_detection = HandDetection(0)
# 複数のインスタンスがある場合
hand_detection_1 = HandDetection(1)
パラメーター
| 名前 | 区分 | 説明 | 範囲・種類 | デフォルト値 |
|---|---|---|---|---|
| index | ドロップダウンオプション | インスタンス番号(0 から始まる) | 0 以上の整数 | 0 |
カメラを設定
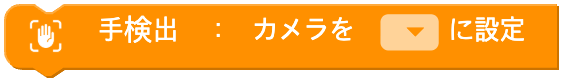
手検出に使うカメラを設定します。
パラメーター
| 名前 | 区分 | 説明 | 範囲・種類 | デフォルト値 |
|---|---|---|---|---|
| unit | ドロップダウンオプション | カメラ機器の名前 | システムのカメラのラベル | - |
Python
python
hand_detection = HandDetection(0)

hand_detection.device('')
手モデルを読み込む
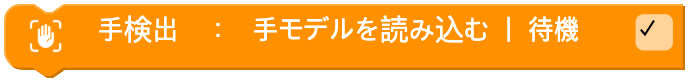
学習済みの手モデルを読み込みます。「手検出」モジュールの機能を使うには、この操作が必ず必要です。
パラメーター
| 名前 | 区分 | 説明 | 範囲・種類 | デフォルト値 |
|---|---|---|---|---|
| wait | チェックボックス | 読み込みの完了を待つかどうか | TRUE / FALSE | TRUE |
Python
python
hand_detection = HandDetection(0)

hand_detection.load_model(wait=True)
対象の手の数を設定
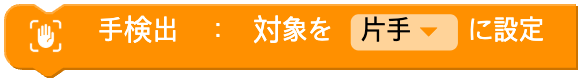
手を検出するとき、片手を対象にするか、両手を対象にするかを決めます。
パラメーター
| 名前 | 区分 | 説明 | 範囲・種類 | デフォルト値 |
|---|---|---|---|---|
| unit | ドロップダウンオプション | 手の数 | 片手(one), 両手(both) | - |
Python
python
hand_detection = HandDetection(0)

hand_detection.max_hands('one')
hand_detection.max_hands('both')
手を1回検出
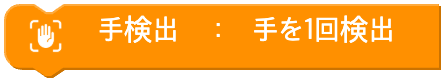
いま画面にある手を見つけて、1 回だけ表示します。
パラメーター
(なし)
Python
python
hand_detection = HandDetection(0)

hand_detection.detect_once()
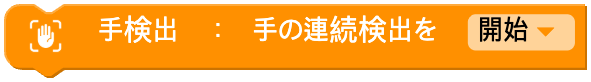
手の連続検出を開始 / 停止
いま画面にある手を続けて追いかけながら、画面上に表示します。
パラメーター
| 名前 | 区分 | 説明 | 範囲・種類 | デフォルト値 |
|---|---|---|---|---|
| unit | ドロップダウンオプション | 動作 | 開始(start), 停止(stop) | - |
Python
python
hand_detection = HandDetection(0)

# unit = "start"
hand_detection.detect_continuous()
# unit = "stop"
hand_detection.stop()
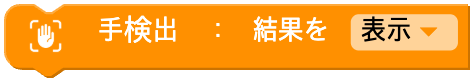
結果を表示
カメラの画面に手検出の結果を表示するかどうかを決めます。
パラメーター
| 名前 | 区分 | 説明 | 範囲・種類 | デフォルト値 |
|---|---|---|---|---|
| on | ドロップダウンオプション | 表示 ON / OFF | 表示(on=True), 非表示(off=False) | TRUE |
Python
python
hand_detection = HandDetection(0)

hand_detection.display(True)
hand_detection.display(False)
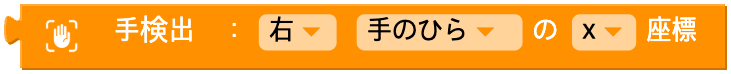
手の部位の座標
指定した手の手のひら/手首の位置の情報を返します。
パラメーター
| 名前 | 区分 | 説明 | 範囲・種類 | デフォルト値 |
|---|---|---|---|---|
| side | ドロップダウンオプション | 手の左右 | 左(left), 右(right) | - |
| unit | ドロップダウンオプション | 手の部位 | 手のひら(palm), 手首(wrist) | - |
| pos | ドロップダウンオプション | 座標/大きさの種類 | x, y | - |
Python
python
hand_detection = HandDetection(0)

hand_detection.hand('left', 'palm', 'x')
hand_detection.hand('right', 'wrist', 'y')
hand_detection.hand('left', 'hand', 'min_x')
hand_detection.hand('right', 'palm', 'width')
指の関節の座標
指定した指の関節の座標を返します。

パラメーター
| 名前 | 区分 | 説明 | 範囲・種類 | デフォルト値 |
|---|---|---|---|---|
| side | ドロップダウンオプション | 手の左右 | 左(left), 右(right) | - |
| unit | ドロップダウンオプション | 指 | 親指(thumb), 人差し指(index), 中指(middle), 薬指(ring), 小指(pinky) | - |
| joint | ドロップダウンオプション | 関節の位置 | 第1関節(first), 第2関節(second), 第3関節(third), 先端(last) | - |
| pos | ドロップダウンオプション | 座標 | x, y | - |
Python
python
hand_detection = HandDetection(0)

hand_detection.finger('left', 'index', 'first', 'x')
hand_detection.finger('right', 'thumb', 'last', 'y')
手の長方形の情報
指定した手の領域の長方形の位置/大きさの値を返します。

パラメーター
| 名前 | 区分 | 説明 | 範囲・種類 | デフォルト値 |
|---|---|---|---|---|
| side | ドロップダウンオプション | 手の左右 | 左(left), 右(right) | - |
| unit | ドロップダウンオプション | 手の部位 | 手(hand), 手のひら(palm) | - |
| pos | ドロップダウンオプション | 長方形の情報 | 最小X位置(min_x), 最大X位置(max_x), 最小Y位置(min_y), 最大Y位置(max_y), 幅(width), 高さ(height), 面積(area) | - |
Python
python
hand_detection = HandDetection(0)

hand_detection.hand('left', 'hand', 'min_x')
hand_detection.hand('right', 'palm', 'width')
手と手の間の距離
2 つの手の部位の間の距離を返します。

パラメーター
| 名前 | 区分 | 説明 | 範囲・種類 | デフォルト値 |
|---|---|---|---|---|
| unit1 | 入力値(文字列) | 1 つ目の手の部位 | 手: 'side_unit'(例: 'left_palm')。side=left/right, unit=palm/wrist/hand | - |
| unit2 | 入力値(文字列) | 2 つ目の手の部位 | 手: 'side_unit'(例: 'right_palm')。side=left/right, unit=palm/wrist/hand | - |
| type | ドロップダウンオプション | 距離の種類 | 距離(省略または None), 横の距離(horizontal), 縦の距離(vertical) | None |
Python
python
hand_detection = HandDetection(0)

# 手 ↔ 手 / 距離
hand_detection.get_distance('left_palm', 'right_palm')
手と指の間の距離
手の部位と指の関節の間の距離を返します。

パラメーター
| 名前 | 区分 | 説明 | 範囲・種類 | デフォルト値 |
|---|---|---|---|---|
| unit1 | 入力値(文字列) | 1 つ目の部位 | 手: 'side_unit'(例: 'left_palm')。side=left/right, unit=palm/wrist/hand | - |
| unit2 | 入力値(文字列) | 2 つ目の部位 | 指: 'side_unit_joint'(例: 'right_index_first')。unit=thumb/index/middle/ring/pinky, joint=first/second/third/last | - |
| type | ドロップダウンオプション | 距離の種類 | 距離(省略または None), 横の距離(horizontal), 縦の距離(vertical) | None |
Python
python
hand_detection = HandDetection(0)

# 手 ↔ 指の関節 / 横の距離
hand_detection.get_distance('left_palm', 'right_index_first')
指と指の間の距離
2 つの指の関節の間の距離を返します。

パラメーター
| 名前 | 区分 | 説明 | 範囲・種類 | デフォルト値 |
|---|---|---|---|---|
| unit1 | 入力値(文字列) | 1 つ目の部位 | 指: 'side_unit_joint'(例: 'left_thumb_last')。unit=thumb/index/middle/ring/pinky, joint=first/second/third/last | - |
| unit2 | 入力値(文字列) | 2 つ目の部位 | 指: 'side_unit_joint'(例: 'right_index_first')。unit=thumb/index/middle/ring/pinky, joint=first/second/third/last | - |
| type | ドロップダウンオプション | 距離の種類 | 距離(省略または None), 横の距離(horizontal), 縦の距離(vertical) | None |
Python
python
hand_detection = HandDetection(0)

# 指の関節 ↔ 指の関節 / 縦の距離
hand_detection.get_distance('left_thumb_last', 'right_index_first', 'vertical')
手モデルの読み込み状態
手モデルの読み込み状態を返します。
まだ読み込んでいなければ 0、読み込み中なら 1、読み込みが完了していれば 2 を返します。
パラメーター
(なし)
Python
python
hand_detection = HandDetection(0)

hand_detection.model_state()
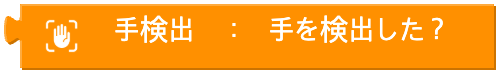
手を検出した?
手を見つけたかどうか
パラメーター
(なし)
Python
python
hand_detection = HandDetection(0)

hand_detection.detected()