
RaccoonBot
Instance declaration
When you add a RaccoonBot block to the workspace, the following instance declaration is automatically inserted into the Python code:
raccoon = RaccoonBot(0)
# When there are multiple instances
raccoon_1 = RaccoonBot(1)
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| index | Dropdown option | Instance number (starting from 0) | Integer 0 or greater | 0 |
Turn joint motor control on / off
Decides whether to release or keep the control applied to each joint motor.
If you do not set it, all joints start with motor control turned on.
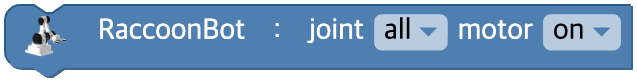
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| unit | Dropdown option | Joint number | all (-1), 1 (1), 2 (2), 3 (3), 4 (4) | -1 |
| on | Checkbox | Motor control ON / OFF | TRUE / FALSE | TRUE |
Python
raccoon = RaccoonBot(0)

# All joints, motor control off
raccoon.motor(-1, False)

# Joint no. 1, motor control on
raccoon.motor(1, True)
Set joint speed
Sets the speed of the selected joint.
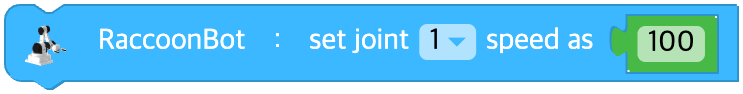
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| joint | Dropdown option | Joint number | all (-1), 1 (1), 2 (2), 3 (3), 4 (4) | - |
| data | Input (block) | Joint speed | Integer -100 to 100 | - |
Python
raccoon = RaccoonBot(0)

raccoon.set_speed_joint(1, 100)
Change joint speed
Changes the speed of the selected joint.
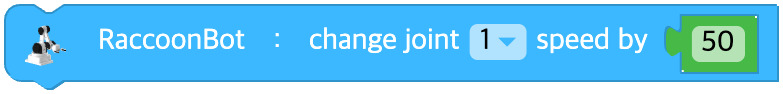
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| joint | Dropdown option | Joint number | all (-1), 1 (1), 2 (2), 3 (3), 4 (4) | - |
| data | Input (block) | Amount of speed change | Integer -200 to 200 | - |
Python
raccoon = RaccoonBot(0)

raccoon.change_speed_joint(1, 50)
Set all joint speeds at once
Sets the speed of all four joints at once.
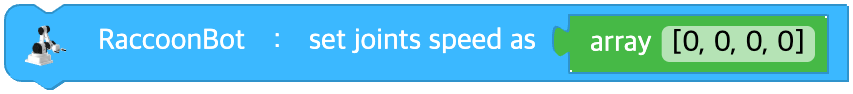
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| data | Input (array) | Array of the four joint speeds | [joint1, joint2, joint3, joint4], each -100 to 100 | - |
Python
raccoon = RaccoonBot(0)

# Literal array [10, 20, 30, 40]
raccoon.set_speed_joints(10, 20, 30, 40)

# Array in a variable
raccoon.set_speed_joints(*arr)
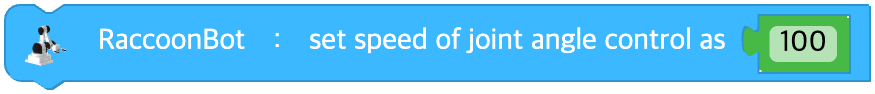
Set the speed of joint angle control
Sets the speed at which joints are controlled in angle control mode.
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| data | Input (block) | Maximum speed of angle control | Integer 0 to 100 | - |
Python
raccoon = RaccoonBot(0)

raccoon.angle_max_speed(100)
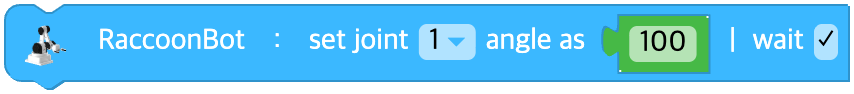
Set joint angle
Sets the angle of the selected joint.
| joint | min | max |
|---|---|---|
| 1 | -120 | 120 |
| 2 | -90 | 30 |
| 3 | -150 | 0 |
| 4 | -105 | 105 |
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| joint | Dropdown option | Joint number | all (-1), 1 (1), 2 (2), 3 (3), 4 (4) | - |
| data | Input (block) | Joint angle (degrees) | See the table above (clamped automatically) | - |
| wait | Checkbox | Whether to wait for completion | TRUE / FALSE | TRUE |
Python
raccoon = RaccoonBot(0)

raccoon.set_angle_joint(1, 90, wait=True)
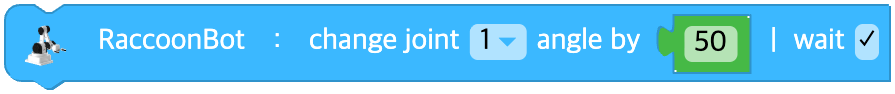
Change joint angle
Changes the angle of the selected joint.
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| joint | Dropdown option | Joint number | all (-1), 1 (1), 2 (2), 3 (3), 4 (4) | - |
| data | Input (block) | Amount of angle change (degrees) | See the table above (clamped automatically) | - |
| wait | Checkbox | Whether to wait for completion | TRUE / FALSE | TRUE |
Python
raccoon = RaccoonBot(0)

raccoon.change_angle_joint(1, 10, wait=True)
Set all joint angles at once
Sets the angle of all four joints at once.

Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| data | Input (array) | Array of the four joint angles, or a posture name | [j1, j2, j3, j4] array | - |
| wait | Checkbox | Whether to wait for completion | TRUE / FALSE | TRUE |
Python
raccoon = RaccoonBot(0)

# Explicit array
raccoon.set_angle_joints(0, 0, 0, 0, wait=True)
Initialize the joint state
Sets the angle of all four joints to a predefined posture ('zero', 'park', 'home').

Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| data | Dropdown | Posture name | 'zero' / 'park' / 'home' | - |
| wait | Checkbox | Whether to wait for completion | TRUE / FALSE | TRUE |
Posture presets:
'zero'→[0, 0, 0, 0]'park'→[0, 25, -145, -60]'home'→[0, -10, -140, 60]
Python
raccoon = RaccoonBot(0)

# Posture preset
raccoon.set_angle_joints('home', wait=True)
Save the joint angles
Saves the current encoder values to a variable of your choice.

Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| encoder | Variable | Name of the variable to save to | Variable | - |
| data | Input (array) | Initial array to save | A 4-element array or an empty array | - |
Python
raccoon = RaccoonBot(0)
encoder = None

encoder = raccoon.save_encoder([3, -6, -73, 60])
Set a particular coordinate value
Moves the robot arm by setting a particular coordinate value.
The range of each coordinate is as follows.
Relative to the wrist => x: -20.0 cm to 20.0 cm, y: -10.0 cm to 20.0 cm, z: -2.0 mm to 28.0 cm
Relative to the gripper => the range can differ depending on the device you connect.
The direction of the gripper is fixed either horizontal or vertical to the ground.
If you enter a coordinate that cannot be reached, the command is skipped.

Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| origin | Dropdown option | Origin | wrist, end effector (end_effector) | - |
| pos | Dropdown option | Axis | x, y, z | - |
| data | Input (block) | Coordinate value | x: -20 to 20 cm, y: -10 to 20 cm, z: -2 to 28 cm | - |
| unit | Dropdown option | Unit | cm, mm, inch | cm |
| wait | Checkbox | Whether to wait for completion | TRUE / FALSE | TRUE |
Python
raccoon = RaccoonBot(0)

# Set the x coordinate to 10 cm
raccoon.set_coordinate('wrist', 'x', 10, 'cm', wait=True)

# The z coordinate relative to end_effector
raccoon.set_coordinate('end_effector', 'z', 15, 'cm', wait=True)
Change a particular coordinate value
Moves the robot arm by changing a particular coordinate value relative to the current position.
The range of each coordinate is as follows.
Relative to the wrist => x: -20.0 cm to 20.0 cm, y: -10.0 cm to 20.0 cm, z: -2.0 mm to 28.0 cm
Relative to the gripper => the range can differ depending on the device you connect.
The direction of the gripper is fixed either horizontal or vertical to the ground.
If you enter a coordinate that cannot be reached, the command is skipped.

Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| origin | Dropdown option | Origin | wrist, end effector (end_effector) | - |
| pos | Dropdown option | Axis | x, y, z | - |
| data | Input (block) | Amount of coordinate change | Real number | - |
| unit | Dropdown option | Unit | cm, mm, inch | cm |
| wait | Checkbox | Whether to wait for completion | TRUE / FALSE | TRUE |
Python
raccoon = RaccoonBot(0)

raccoon.change_coordinate('wrist', 'y', 5, 'cm', wait=True)
Move to xyz coordinates
Sets the x, y, and z coordinates to the specified values all at once.

Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| origin | Dropdown option | Origin | wrist, end effector (end_effector) | - |
| x | Input (block) | x coordinate | Real number | - |
| y | Input (block) | y coordinate | Real number | - |
| z | Input (block) | z coordinate | Real number | - |
| unit | Dropdown option | Unit | cm, mm, inch | cm |
| wait | Checkbox | Whether to wait for completion | TRUE / FALSE | TRUE |
Python
raccoon = RaccoonBot(0)

raccoon.set_coordinates('wrist', 0, 15, 20, 'cm', wait=True)
Set the end effector lock
Sets the direction in which the gripper is locked. Once the option is set to horizontal or vertical, you can no longer control the speed or angle of joint 4.

Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| mode | Dropdown option | Lock direction | none, horizontal, vertical | - |
Python
raccoon = RaccoonBot(0)

raccoon.lock('horizontal')
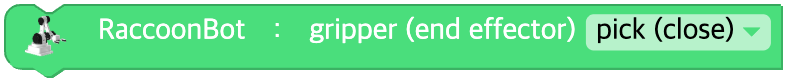
Pick / place an object with the end effector
Picks up or places an object with the end effector.
Depending on the unit dropdown value, one of two methods is called.
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| unit | Dropdown option | Action | pick (close), place (open) | - |
Python
raccoon = RaccoonBot(0)

# unit = "pick"
raccoon.pick()
# unit = "place"
raccoon.place()
End effector device
The number of the gripper currently connected
(1, 3, 4: tong gripper, 2: vacuum gripper)
Parameters
(none)
Python
raccoon = RaccoonBot(0)

raccoon.end_effector_device()
End effector status
Whether the gripper is holding an object
(0: released, 1: holding)
Parameters
(none)
Python
raccoon = RaccoonBot(0)

raccoon.end_effector_status()
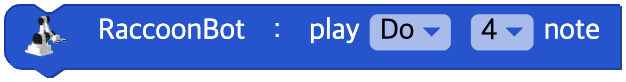
Play a note
RaccoonBot plays the specified note.
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| note | Dropdown option | Note | Do (C), Do# (C#), Re (D), Re# (D#), Mi (E), Fa (F), Fa# (F#), Sol (G), Sol# (G#), La (A), La# (A#), Si (B) | - |
| octave | Dropdown option | Octave | 1, 2, 3, 4, 5, 6, 7 | 4 |
Python
raccoon = RaccoonBot(0)

raccoon.sound_note('D', 5)
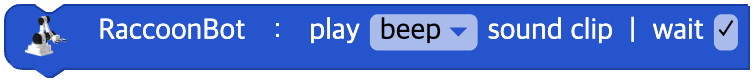
Play a sound clip
RaccoonBot plays a particular sound clip.
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| clip | Dropdown option | Sound clip name | 'mute', 'beep', 'siren', 'robot', 'connect', 'wake_up', 'start', 'bye', and so on | - |
| wait | Checkbox | Whether to wait for completion | TRUE / FALSE | TRUE |
Python
raccoon = RaccoonBot(0)

raccoon.sound_clip('siren', wait=True)
Sound off
Turns off the sound of RaccoonBot.
Parameters
(none)
Python
raccoon = RaccoonBot(0)

raccoon.sound_off()
Encoder value
The encoder value of the selected joint
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| joint | Dropdown option | Joint number (or all joints) | 1, 2, 3, 4, all (-1) | -1 |
Python
raccoon = RaccoonBot(0)

# joint = 1
raccoon.encoder(1)

# All joints
raccoon.encoder(-1)
Coordinate of the selected element
Returns the current xyz coordinates of the reference point.
If you omit pos, it returns the whole [x, y, z] array; if you specify it, it returns only that axis value.
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| origin | Dropdown option | Origin | wrist, end effector (end_effector) | wrist |
| pos | Dropdown option | Axis (or all) | x, y, z, xyz (omit to return the whole array) | None (all) |
Python
raccoon = RaccoonBot(0)

# A particular axis
raccoon.get_coordinates('wrist', 'x')

# All (a 3-element array)
raccoon.get_coordinates('wrist')
Signal strength value
The signal strength
Parameters
(none)
Python
raccoon = RaccoonBot(0)

raccoon.signal_strength()
Battery voltage
The battery voltage
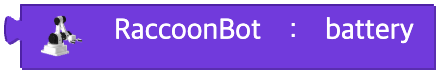
Parameters
(none)
Python
raccoon = RaccoonBot(0)

raccoon.battery()
Is the button pressed?
Whether the selected button is pressed or a click event has occurred
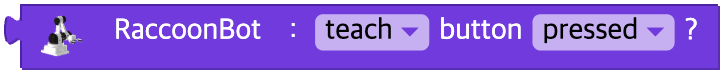
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| unit | Dropdown option | Button name | teach, play, power, delete, any | - |
| event | Dropdown option | Kind of event | pressed, click, long click (long_click) | - |
Python
raccoon = RaccoonBot(0)

raccoon.button('teach', 'pressed')
Set the conveyor speed
Sets the speed of the conveyor belt. The speed ranges from -100 to 100.
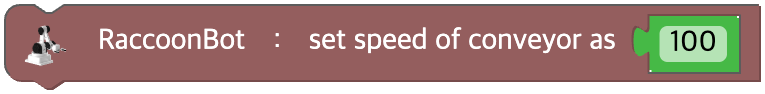
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| data | Input (block) | Conveyor speed | Integer -100 to 100 | - |
Python
raccoon = RaccoonBot(0)

raccoon.set_conveyor_speed(100)
Set the conveyor travel distance
Moves the conveyor a certain distance.
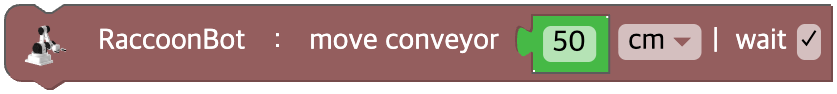
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| data | Input (block) | Distance to move | Real number 0 or greater | - |
| unit | Dropdown option | Distance unit | cm, mm, inch | cm |
| wait | Checkbox | Whether to wait for completion | TRUE / FALSE | TRUE |
Python
raccoon = RaccoonBot(0)

raccoon.conveyor_move(50, 'cm', wait=True)
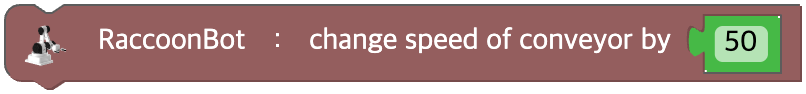
Change the conveyor speed
Changes the speed of the conveyor belt.
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| data | Input (block) | Amount of speed change | Integer -200 to 200 | - |
Python
raccoon = RaccoonBot(0)

raccoon.change_conveyor_speed(10)
Stop the conveyor
Stops the conveyor.
Parameters
(none)
Python
raccoon = RaccoonBot(0)

raccoon.stop_conveyor()
Is the conveyor running?
Whether the conveyor belt is running
Parameters
(none)
Python
raccoon = RaccoonBot(0)

raccoon.conveyor_running()
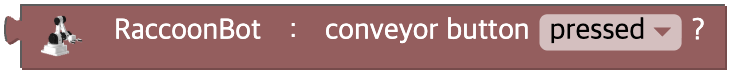
Is the conveyor button pressed?
Whether the button on the conveyor is pressed or a click event has occurred
Parameters
| Name | Kind | Description | Range / Type | Default |
|---|---|---|---|---|
| event | Dropdown option | Kind of event | pressed, click, long click (long_click) | - |
Python
raccoon = RaccoonBot(0)

raccoon.conveyor_button('pressed')