
Beagle
声明实例
把 Beagle 积木添加到工作区后,Python 代码中会自动插入下面这样的实例声明:
beagle = Beagle(0)
# 有多个实例时
beagle_1 = Beagle(1)
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| index | 下拉选项 | 实例编号(从 0 开始) | 0 以上的整数 | 0 |
设置轮速度
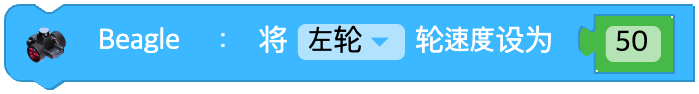
决定轮速度。速度的范围是 -100 ~ 100。
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| unit | 下拉选项 | 车轮种类 | 左轮(left), 右轮(right), 两轮(both) | - |
| speed | 输入值(积木) | 轮速度 | -100 ~ 100 的整数, 0: 停止 | - |
Python
beagle = Beagle(0)

beagle.set_wheel_speed('both', 50)
移动指定距离
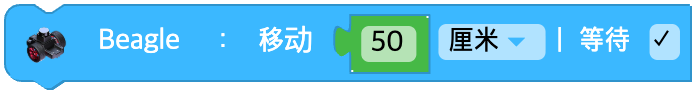
以当前的轮速度移动指定的距离。
如果没有设置轮速度,就以默认速度向前移动。
距离值为 0 时,按当前的轮速度持续移动。
勾选等待后,会一直等到移动完成。
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| data | 输入值(积木) | 移动距离 | 0 以上的实数 | - |
| unit | 下拉选项 | 距离单位 | 厘米(cm), 毫米(mm), 英寸(inch) | cm |
| wait | 复选框 | 是否等待完成 | TRUE / FALSE | TRUE |
Python
beagle = Beagle(0)

beagle.move_distance(50, 'cm', wait=True)
移动指定时间
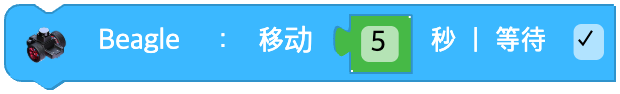
以当前的轮速度移动指定的时间。
如果没有设置轮速度,就以默认速度向前移动。
勾选等待后,会一直等到移动完成。
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| data | 输入值(积木) | 移动时间(秒) | 0 以上的实数 | - |
| wait | 复选框 | 是否等待完成 | TRUE / FALSE | TRUE |
Python
beagle = Beagle(0)

# wait = TRUE
beagle.move_time(5, wait=True)
# wait = FALSE
beagle.move_time(0.5, wait=False)
原地转动
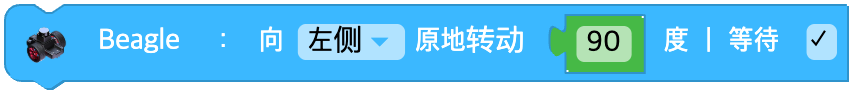
设置原地旋转的方向和角度。
勾选等待后,会一直等到旋转完成。
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| direction | 下拉选项 | 旋转方向 | 左侧(left), 右侧(right) | - |
| data | 输入值(积木) | 旋转角度(度) | 0 以上的实数 | - |
| wait | 复选框 | 是否等待完成 | TRUE / FALSE | TRUE |
Python
beagle = Beagle(0)

beagle.turn_degree('left', 90, wait=True)
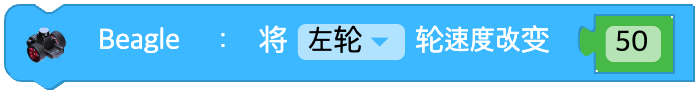
改变轮速度
改变 Beagle 的轮速度。
在当前的轮速度上加上输入的速度,得到新的轮速度。
新设置的轮速度范围会限制在 -100 ~ 100。
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| unit | 下拉选项 | 车轮种类 | 左轮(left), 右轮(right), 两轮(both) | - |
| speed | 输入值(积木) | 要改变的速度差 | -200 ~ 200 的整数 | - |
Python
beagle = Beagle(0)

beagle.change_wheel_speed('both', 10)
停止
让 Beagle 停止移动。
Beagle 两轮的速度都会初始化为 0。
参数
(无)
Python
beagle = Beagle(0)

beagle.stop()
车轮正在移动?
车轮正在移动时返回 true,停止时返回 false。
参数
(无)
Python
beagle = Beagle(0)

beagle.wheel_moving()
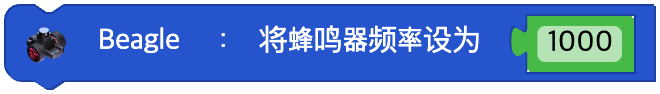
设置蜂鸣器频率
以指定的频率设置 Beagle 的蜂鸣器声音。
可以发声的频率范围是 27.5hz ~ 6553.5hz。
输入其他值时不会发出蜂鸣声。
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| hz | 输入值(积木) | 频率(Hz) | 0, 27.5 ~ 6553.5 的实数(其他为 0) | - |
Python
beagle = Beagle(0)

beagle.sound_buzz(440)
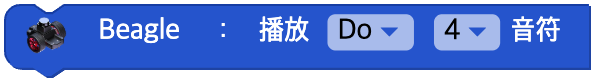
播放音符
Beagle 播放指定的音符。
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| note | 下拉选项 | 音符 | Do(C), Do#(C#), Re(D), Re#(D#), Mi(E), Fa(F), Fa#(F#), Sol(G), Sol#(G#), La(A), La#(A#), Si(B) | - |
| octave | 下拉选项 | 八度 | 1, 2, 3, 4, 5, 6, 7 | 4 |
Python
beagle = Beagle(0)

beagle.sound_note('D', 5)
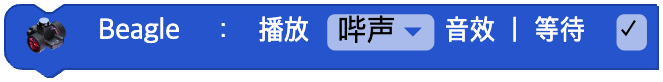
播放音效
Beagle 播放特定的声音片段。
勾选等待后,会一直等到播放完成。
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| clip | 下拉选项 | 声音片段名称 | 'mute', 'beep', 'siren', 'engine', 'robot', 'dibidibidip', 'happy', 'angry', 'sad', 'sleep', 'march', 'birthday' 等 | - |
| wait | 复选框 | 是否等待完成 | TRUE / FALSE | TRUE |
Python
beagle = Beagle(0)

beagle.sound_clip('siren', wait=True)
关闭声音
关闭 Beagle 的声音。
参数
(无)
Python
beagle = Beagle(0)

beagle.sound_off()
正在播放声音?
声音正在播放时返回 true,没有播放时返回 false。
参数
(无)
Python
beagle = Beagle(0)

beagle.sound_playing()
轮速度值
特定车轮的速度
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| unit | 下拉选项 | 目标车轮 | 左侧(left), 右侧(right) | - |
Python
beagle = Beagle(0)

beagle.wheel_speed('left')
编码器值
特定车轮的编码器值
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| unit | 下拉选项 | 目标车轮 | 左侧(left), 右侧(right) | - |
Python
beagle = Beagle(0)

beagle.encoder('left')
陀螺仪值
特定轴的陀螺仪传感器的值
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| unit | 下拉选项 | 测量的轴 | x, y, z | - |
Python
beagle = Beagle(0)

beagle.gyroscope('x')
加速度计值
特定轴的加速度传感器的值
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| unit | 下拉选项 | 测量的轴 | x, y, z | - |
Python
beagle = Beagle(0)

beagle.accelerometer('x')
磁力计值
特定轴的地磁传感器的值
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| unit | 下拉选项 | 测量的轴 | x, y, z | - |
Python
beagle = Beagle(0)

beagle.magnetometer('x')
温度传感器值
温度传感器值
参数
(无)
Python
beagle = Beagle(0)

beagle.temperature()
信号强度值
信号强度
参数
(无)
Python
beagle = Beagle(0)

beagle.signal_strength()
电池电压
电池电压
参数
(无)
Python
beagle = Beagle(0)

beagle.battery()
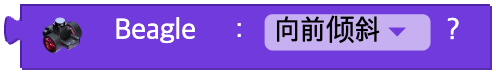
状态是否改变
机器人的状态是否发生了改变
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| unit | 下拉选项 | 状态种类 | 0 ~ 5(参见下表) | - |
| unit | 条件 |
|---|---|
| 0 | accelerometer('x') > 0.8 |
| 1 | accelerometer('x') < -0.8 |
| 2 | accelerometer('y') > 0.8 |
| 3 | accelerometer('y') < -0.8 |
| 4 | accelerometer('z') > 0 |
| 5 | accelerometer('z') < 0 |
Python
beagle = Beagle(0)

# unit = 0
beagle.accelerometer('x') > 0.8
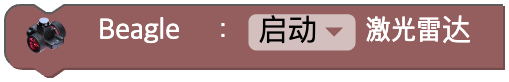
启动 / 停止激光雷达
启用或停用激光雷达传感器。
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| on | 下拉选项 | 激光雷达 ON / OFF | 启动(on=True), 停止(off=False) | TRUE |
Python
beagle = Beagle(0)

beagle.lidar_power(True)
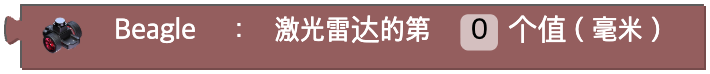
激光雷达第 ~ 个值
激光雷达传感器可以测量周围 360 度范围内与物体的距离。
以 Beagle 的前方(第 0 个值)为基准,沿逆时针方向编号每次加 1。
参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| unit | 输入值(字段) | 物体编号(从 0 开始) | 0 以上的整数 | - |
Python
beagle = Beagle(0)

beagle.lidar_value(0)
激光雷达各方向的距离值
表示激光雷达传感器测得的前、后、两侧和斜方向的距离。
输出该方向左右各 45 度范围内距离值的平均值。

参数
| 名称 | 类别 | 说明 | 范围 / 种类 | 默认值 |
|---|---|---|---|---|
| direction | 下拉选项 | 测量方向 | 前方(front), 左前方(left front), 左侧(left), 左后方(left back), 后方(back), 右后方(right back), 右侧(right), 右前方(right front) | - |
Python
beagle = Beagle(0)

beagle.lidar_directions('front')
激光雷达已就绪?
返回激光雷达是否已启动,结果为 true(True) / false(False)。
参数
(无)
Python
beagle = Beagle(0)

beagle.lidar_ready()